Solver performance
A focus on solve speed.
Suspension Explorer's core solver is designed to be performant; single sweeps and batch studies are fast enough to support rapid exploration of your design space.
Suspension Explorer is an open-core geometric constraint solver for simulating and analyzing vehicle suspension kinematics.
Capabilities
Solver performance
Suspension Explorer's core solver is designed to be performant; single sweeps and batch studies are fast enough to support rapid exploration of your design space.
Multiple suspension types
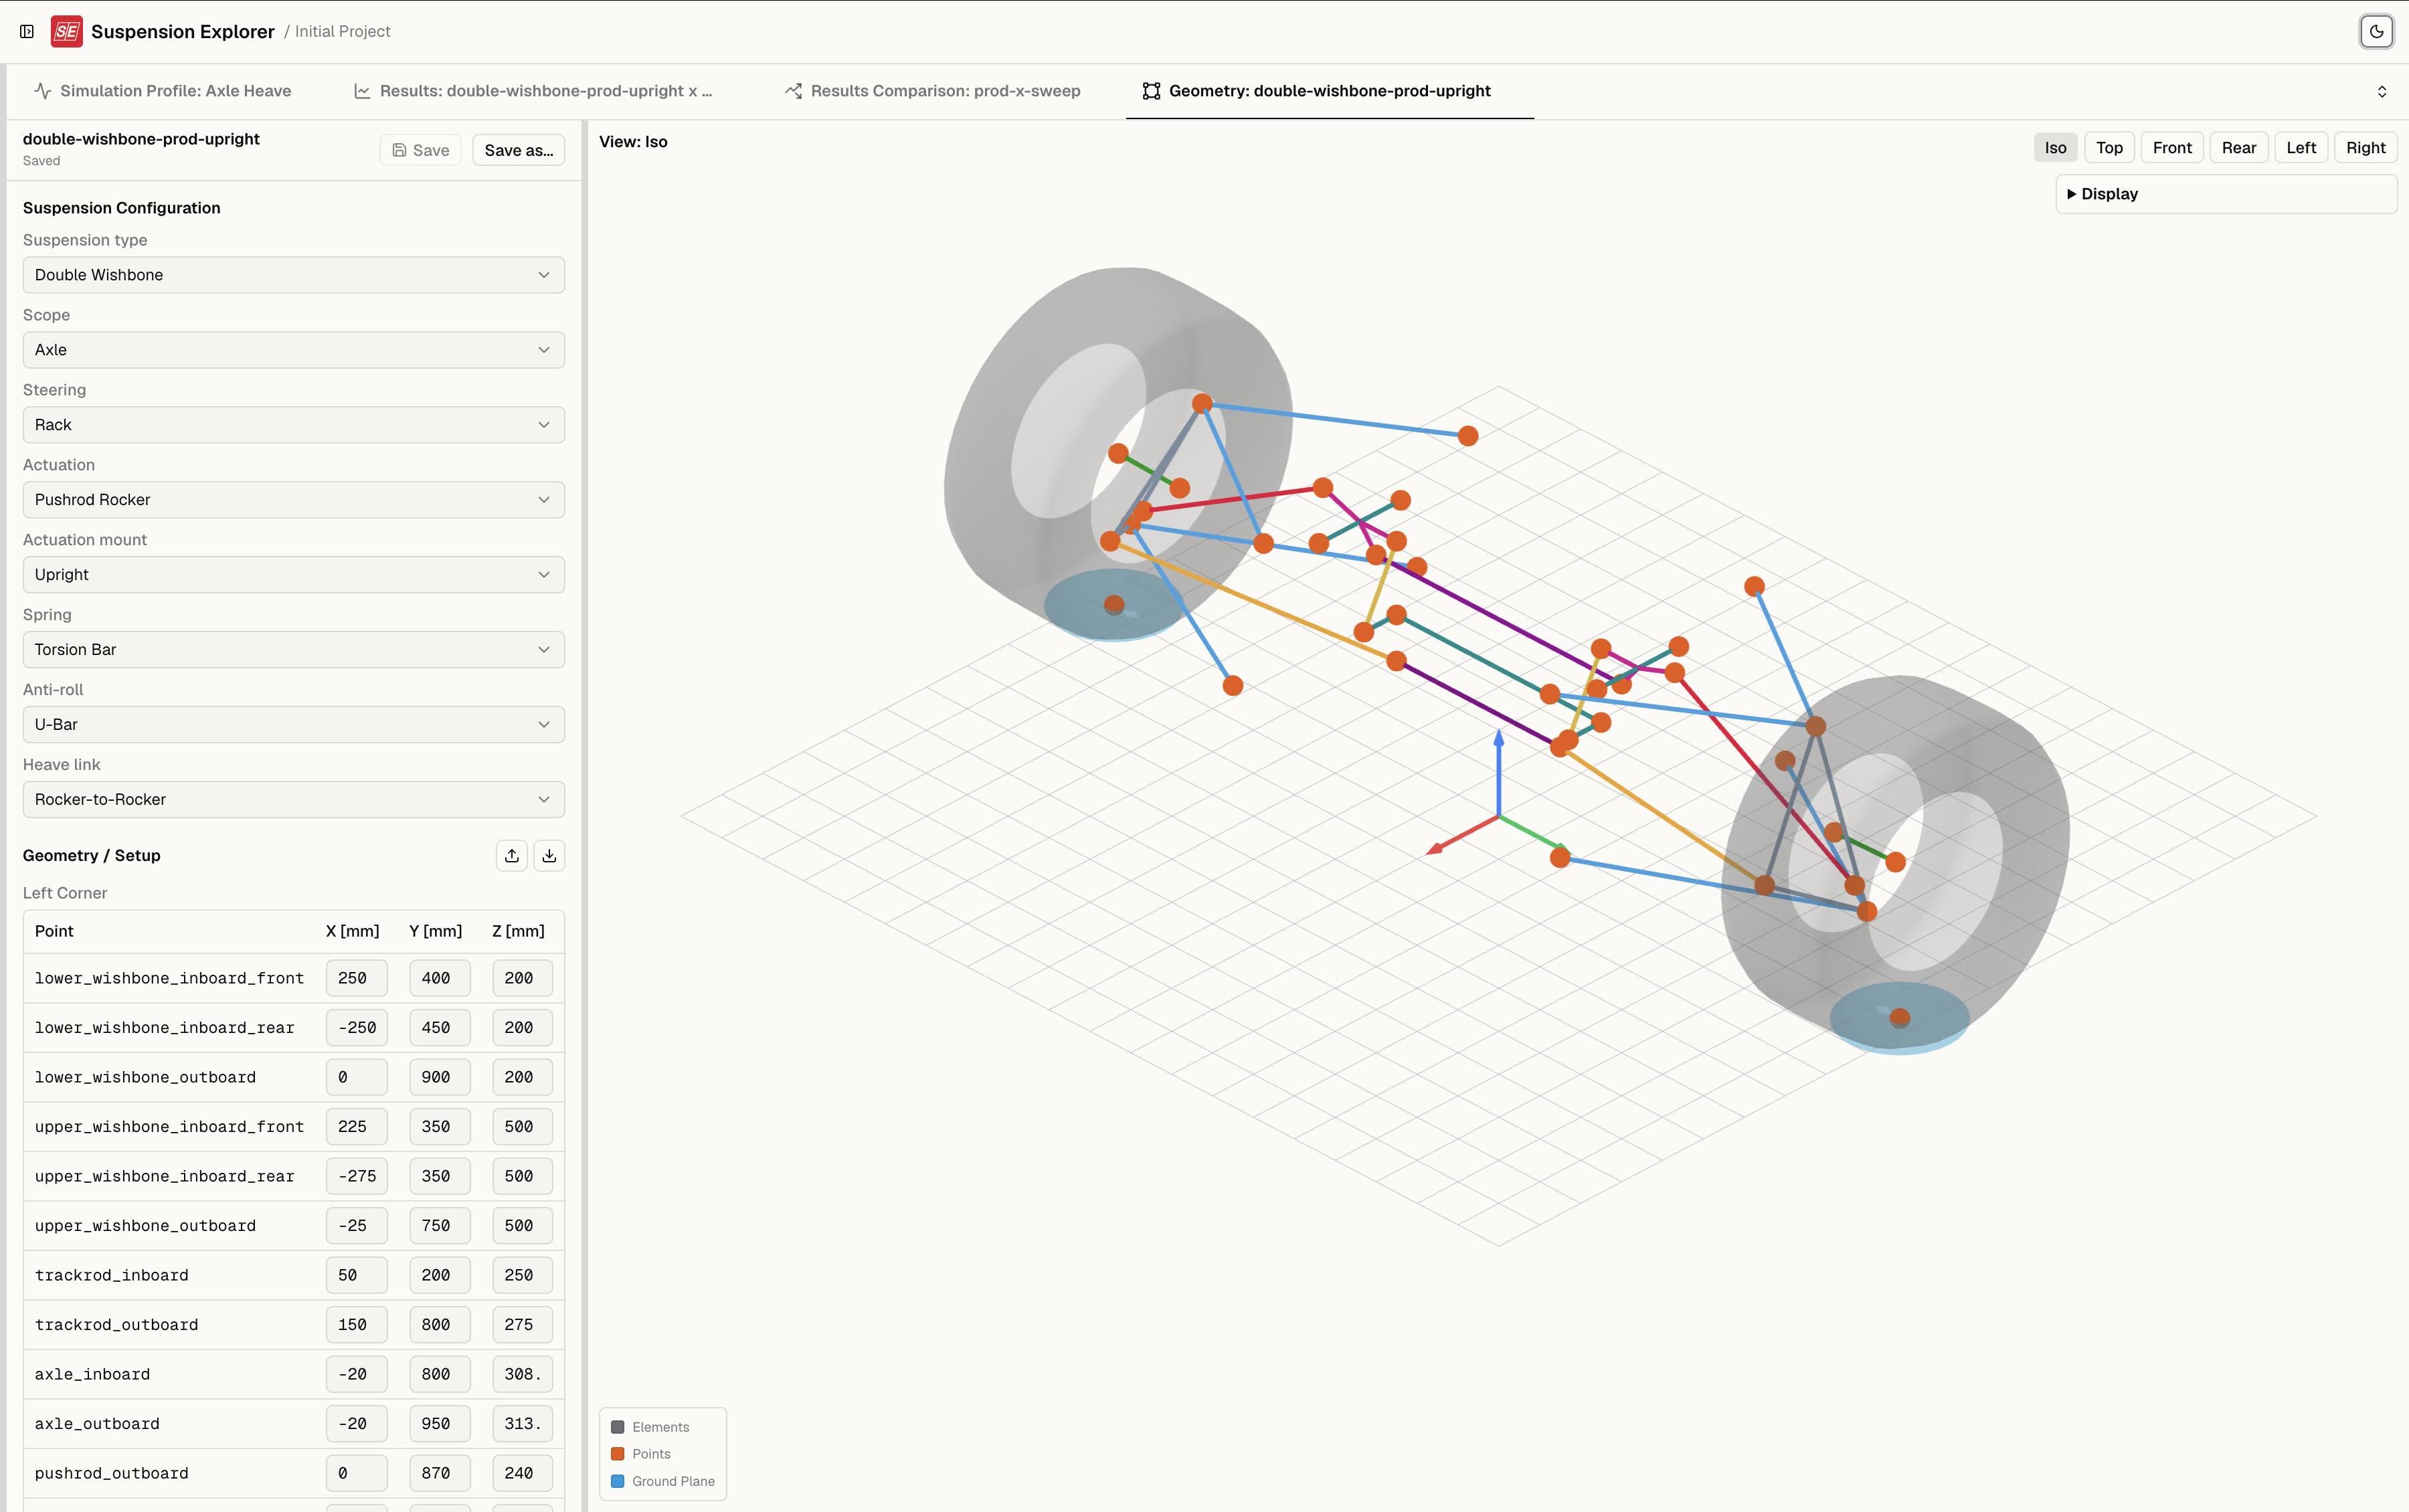
Suspension Explorer supports multiple suspension systems and actuation options, including dedicated heave links. The web app supports coordinated bump, roll, and steer sweeps, and displays results in the browser.
For maximum flexibility, that same solver can be used from your Python environment or directly from the command line.
Solver design
The core solve path mixes explicit derivative formulations with forward-mode automatic differentiation. Reported response derivatives, including motion ratios, are calculated analytically rather than estimated from neighboring sweep step finite differences.
A directed acyclic graph tracks geometry dependencies, allowing derived and imaginary points to drive the solve without becoming independent variables. For example, an ‘imaginary’ stub axle midpoint which does not influence kinematics directly can still be used to drive a sweep.
Two ways to work
Web app
The web app models suspensions from hardpoints, solves coordinated bump, roll, and steer sweeps, and displays motion and metrics in an interactive workspace. No installation required.
Python/CLI
Geometry and sweep definitions can be version-controlled and combined in programmatic studies. Solves run locally, and data stays on the machine.
Open-core model
The same solver that powers the app is available as a standalone Python package under AGPL-3.0-only. The source code and mathematics are available for inspection, and the solver can be run independently and extended.
View the core on GitHub